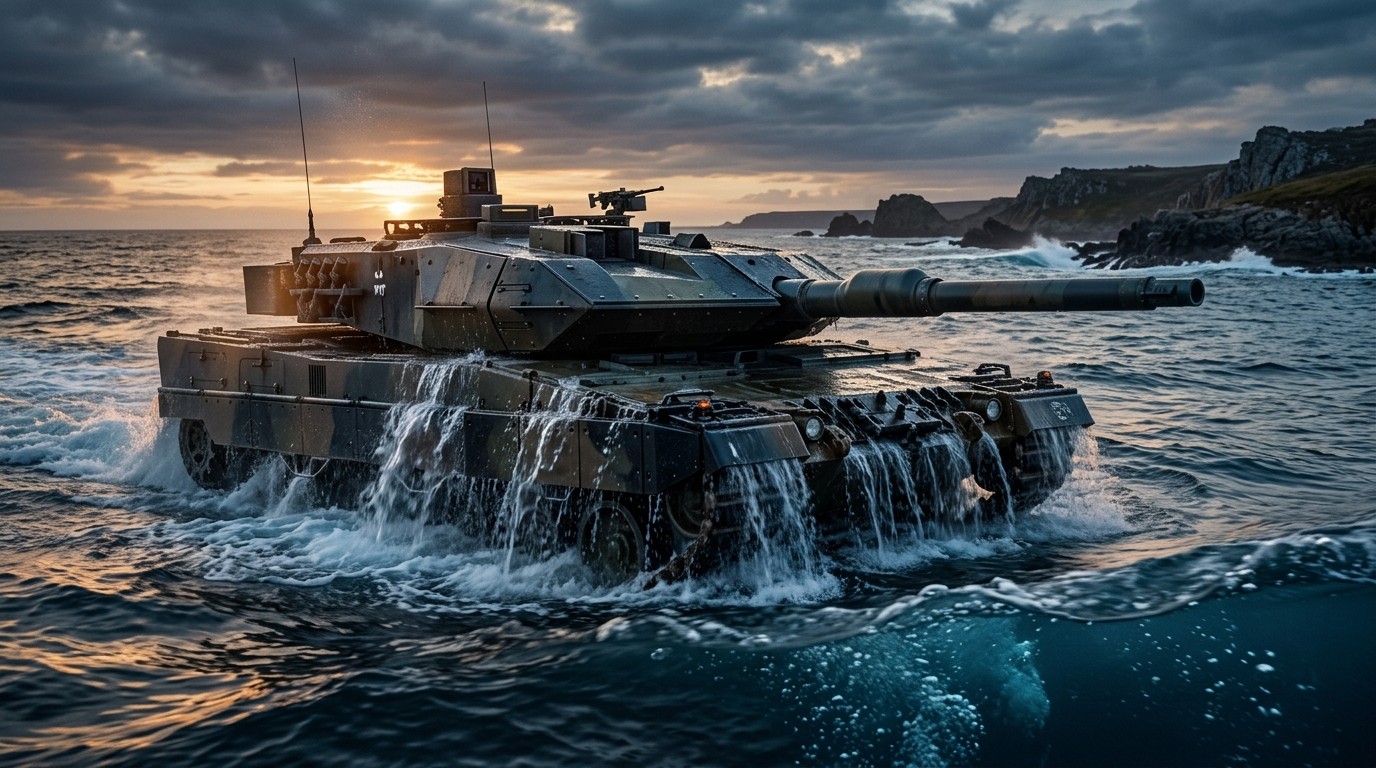

Have you ever wondered what happens when a tank decides to take a long dive? I mean really dive, not just splash through a river for a few minutes. Recent research coming out of China points toward a military vehicle concept that could stay completely submerged for up to two hours. That idea alone stopped me in my tracks when I first read about it. Two full hours underwater at depths reaching 164 feet, then climbing out onto dry land ready to fight. It sounds almost like science fiction, yet teams at major research institutes are treating it as a serious engineering goal for the decades ahead.
A Fresh Look At Amphibious Warfare
Traditional amphibious operations have always carried heavy risks. Landing craft, hovercraft, and specialized ships make tempting targets. Once troops and vehicles hit the beach, the element of surprise is usually long gone. The concept now under development tries to flip that script. Imagine an armored vehicle that approaches the coast while still hidden beneath the surface, then surfaces close to the objective and rolls straight into combat. That shift could reduce the need for large, vulnerable landing fleets.
Researchers from the Inner Mongolia First Machinery Group working with the Beijing Institute of Technology are exploring this path as part of a broader push toward multi-environment platforms. Instead of building one vehicle for land, another for water, and yet another for special missions, they want a single chassis that accepts different modules. Swap a few key components and the same basic vehicle can handle roles that once required entirely separate designs. I find that modular thinking more interesting than the underwater part itself, because it suggests a long-term philosophy rather than a single flashy prototype.
How The Submersible Capability Might Work
Details remain limited, which is normal at this early stage. The published concept describes a vehicle able to travel at depths of roughly 50 meters and remain submerged for two hours. What is still missing is any firm figure for underwater speed or total submerged range. That absence is telling. Surface travel numbers look more concrete: a hybrid power system aiming for a land range of about 600 kilometers and top speeds above 70 kilometers per hour. Response time from threat detection to engagement is targeted at nine seconds. Those figures, if achieved, would place the platform in a competitive class with many current main battle tanks while adding an entirely new dimension.
The hybrid approach makes sense for an underwater role. Diesel engines need air. Pure battery packs struggle with the energy density required for both propulsion and life support systems. A combination of the two, carefully managed, could allow the vehicle to run quietly on electric power while submerged and switch to conventional power once it surfaces. Sealing the hull, managing buoyancy, and keeping the crew alive for two hours present their own set of engineering puzzles. Pressure at 50 meters is significant. Any leak or system failure becomes life-threatening almost immediately.
In my view the real challenge is not staying underwater for two hours once. The hard part is doing it reliably, repeatedly, and while carrying a full combat load. Armor, ammunition, sensors, and crew all add weight and complexity. Every extra kilogram must be balanced against the need to control buoyancy. Too heavy and the vehicle sinks beyond recovery. Too light and it struggles to stay submerged against currents. Getting that balance right across changing fuel loads and ammunition expenditure will demand sophisticated automatic systems.
Modular Design And Multi-Role Ambitions
Perhaps the most practical idea in the whole concept is the emphasis on interchangeable modules. Rather than locking the vehicle into one mission profile, designers want the ability to reconfigure it quickly. One module set might optimize for underwater travel. Another could focus on heavy firepower for land combat. A third might prioritize sensors and drone control. Initial testing of some modular components has already shown promising results, according to the research teams. The underwater package itself still awaits full demonstration.
This modular mindset mirrors trends I have watched in other industries. Commercial truck manufacturers now sell chassis that accept different bodies. Aircraft makers design airframes that can switch between passenger and cargo roles. Applying the same logic to armored vehicles feels logical once you think about the cost of modern military platforms. Building a specialized underwater tank from scratch would be enormously expensive. Creating a flexible platform that can accept an underwater kit when needed looks more efficient over a 20-year service life.
- Interchangeable mission modules for different environments
- Hybrid power system balancing range and quiet operation
- Integration of small drones for obstacle clearance and reconnaissance
- Targeted land performance matching current main battle tanks
- Focus on rapid adaptation rather than single-role specialization
Drones form another interesting piece of the puzzle. The concept includes unmanned systems that could swim ahead of the tank, locate obstacles, or even help clear paths through minefields or underwater barriers. A manned vehicle that can launch and control its own scouts gains a serious advantage in the chaotic first minutes of a landing. Whether those drones would be recovered or treated as expendable remains an open question. Either approach carries cost and logistical implications.
Timeline And Strategic Context
The research sits inside a longer planning window that stretches from 2030 to 2050. That horizon tells us two things. First, nobody expects a finished vehicle on parade next year. Second, the work is meant to shape the next generation of armored forces rather than produce a quick prototype for public display. Long planning cycles allow engineers to explore ideas that look impractical today but might become feasible as materials, batteries, and control systems improve.
Amphibious capability has always mattered to nations with long coastlines or interests across water barriers. The ability to approach a shoreline while remaining largely invisible until the final moments could complicate an opponent’s defensive planning. Coastal defense systems optimized against surface landing craft might struggle against vehicles that surface only a few hundred meters from the beach. Of course every new capability eventually meets a counter. Sensors, underwater detection networks, and specialized munitions would evolve in response. That cycle of measure and countermeasure is as old as warfare itself.
The true value of a multi-environment platform may lie less in any single spectacular feat and more in the flexibility it gives commanders when conditions change without warning.
I keep coming back to the flexibility argument. A force equipped with vehicles that can fight on land, cross rivers, and approach coasts underwater gains options that purely land-bound or purely naval forces lack. Whether those options prove decisive depends on doctrine, training, and the quality of the supporting systems. Hardware alone rarely wins campaigns. Still, hardware that expands the range of possible maneuvers creates opportunities that skilled commanders can exploit.
Technical Hurdles Still Ahead
Several engineering problems stand out. First is energy management. Two hours of submerged operation requires either large battery capacity or a very efficient air-independent system. Both add weight and volume that compete with armor and weapons. Second is crew endurance. The interior of a sealed tank is already cramped and noisy. Adding life-support systems, carbon dioxide scrubbers, and emergency oxygen supplies further reduces living space. Crews would need specialized training for underwater emergencies that land forces rarely face.
Third is communication. Radio waves do not travel well through water. Maintaining contact with higher command or with supporting units while submerged would require either acoustic systems or periodic antenna exposure. Each solution brings its own risks and limitations. Fourth is maintenance. Salt water is harsh on mechanical systems. Seals, electronics, and moving parts would face accelerated wear. Designing components that tolerate repeated immersion without constant overhaul is no small task.
I have watched enough complex military projects to know that the gap between concept paper and reliable field system can span decades. Early modular tests sounding positive is encouraging, yet the underwater package remains unproven. That gap matters. Until a prototype actually dives, stays down for the full two hours, surfaces under control, and then drives away under its own power, the numbers remain theoretical.
Possible Implications For Future Operations
If the concept eventually matures, it could influence how planners think about island chains, river crossings, and contested shorelines. A formation of such vehicles might approach from directions that surface radar and optical sensors struggle to cover. The psychological effect on defenders could be significant. Knowing that armored vehicles might appear from underwater changes the mental map of the battlefield.
At the same time, the technology would demand new support structures. Recovery vessels capable of retrieving a disabled underwater tank, specialized training facilities, and maintenance docks designed for submerged vehicles all add cost. Logistics chains would need to carry spare seals, battery modules, and life-support consumables that conventional tank units never require. Those hidden costs sometimes decide whether a promising idea survives the transition from research to production.
Another angle worth considering is the export potential or the influence on other nations’ research programs. Successful demonstration of even limited underwater endurance would almost certainly spur competing efforts elsewhere. Military technology rarely develops in isolation. One nation’s breakthrough often becomes another nation’s requirement. Whether that competition produces better systems overall or simply more expensive ones remains an open debate.
Comparing Ambition With Current Reality
Existing amphibious vehicles already cross water, but most stay on the surface or operate in very shallow depths for short periods. True submarine capability for a heavy armored vehicle is rare. A few specialized designs have appeared over the decades, usually limited to river crossings or short coastal hops. Extending that performance to two hours at 50 meters represents a clear step beyond those earlier efforts. Whether the step is achievable with current materials and power systems is the central question the research teams must answer.
Hybrid propulsion offers one promising route. Electric drive can be quiet and produce no exhaust while submerged. A compact diesel or turbine generator could recharge batteries or provide direct power once the vehicle surfaces. Managing the transition between modes without losing mobility or creating thermal signatures that enemy sensors can exploit will require careful engineering. Thermal management itself becomes more difficult underwater, where heat has fewer places to go.
| Capability | Target Figure | Current Status |
| Submerged endurance | Up to 2 hours | Concept stage |
| Maximum depth | Approximately 50 meters | Unproven |
| Land range | Around 600 kilometers | Design goal |
| Land speed | Over 70 km/h | Design goal |
| Threat response time | 9 seconds | Design goal |
Looking at the table above, the gap between land performance targets and underwater goals is obvious. The land numbers sit within the range of many modern tanks. The underwater numbers sit in largely unexplored territory for vehicles of this weight class. Bridging that gap will determine whether the concept remains an interesting research paper or becomes a fielded system.
Human Factors And Training Challenges
Technology is only half the story. The people inside the vehicle matter just as much. Operating a sealed tank underwater for two hours introduces stresses that conventional crews never face. Claustrophobia, limited escape options, and the constant awareness that the surrounding environment is hostile all take a psychological toll. Selection and training programs would need to identify individuals who can function under those conditions without degradation of performance.
Emergency procedures become especially critical. If a conventional tank is hit, the crew can often bail out onto solid ground. Underwater, escape is far more complicated. Hatches must function against external pressure. Life rafts or individual escape systems add further weight and complexity. Practicing those procedures safely requires specialized facilities that few armies currently possess. Building that training infrastructure would form part of the overall cost of adopting the concept.
I have always believed that the best military technology amplifies the skill of the people using it rather than trying to replace that skill. A vehicle that can approach a coast underwater still needs a well-trained crew who understand both the tactical situation and the unique limitations of their platform. Over-reliance on the machine’s novelty could prove dangerous if the human element is neglected.
Broader Lessons From Multi-Domain Thinking
The project reflects a wider trend toward multi-domain platforms. Forces around the world are looking for systems that can operate across land, sea, air, and even cyber environments with less friction. A tank that can dive is one expression of that trend. Whether it becomes the dominant expression or remains a niche capability will depend on cost, reliability, and the specific geographic challenges each nation faces.
Some theaters of potential conflict feature long coastlines, numerous islands, or extensive river networks. In those environments an underwater approach capability could prove valuable. In other regions dominated by open plains or dense urban areas, the same capability might see little use. Matching the tool to the likely operational environment remains a fundamental principle of force design. The research teams appear to understand this, framing the work as part of a long-term exploration rather than an immediate procurement program.
One subtle advantage of modular design is the ability to upgrade individual components without replacing the entire vehicle. As battery technology improves, new power modules could be swapped in. Better seals or more efficient life-support systems could follow the same path. That evolutionary approach often proves more sustainable than waiting for a perfect all-new design that never quite arrives.
What Remains Uncertain
Several key questions still lack answers. How fast can the vehicle move while submerged? What is the practical range underwater before batteries or other energy stores are exhausted? How does the crew maintain situational awareness when visual and radio options are limited? How does the platform handle strong currents or unexpected underwater obstacles? Each of these questions will need practical answers before any production decision becomes realistic.
The research teams have been careful not to overclaim. They present the work as exploratory, focused on the 2030-2050 window. That honesty is refreshing. Too many military technology announcements promise near-term miracles that quietly fade once engineering realities set in. By keeping the timeline long and the language measured, the current effort leaves room for genuine progress without the pressure of immediate public demonstration.
In the end I find myself more intrigued by the modular philosophy than by the specific underwater endurance figure. Two hours is an impressive target, yet the deeper idea of a single platform that can be reconfigured for multiple environments feels more transformative. If that approach succeeds, the same logic could spread to other vehicle classes. Artillery systems, command vehicles, and logistics platforms might all benefit from greater adaptability.
Whether this particular concept ever reaches the field remains to be seen. What seems clear is that the underlying questions it raises about flexibility, multi-environment operation, and the future of armored forces will continue to matter. Military technology rarely stands still. Ideas that look ambitious today often become the baseline expectations of the next generation. Watching how this research evolves over the coming years should prove instructive for anyone interested in the direction of modern land and amphibious warfare.
The next steps will likely involve more detailed modeling, component testing, and eventually limited underwater trials. Each successful test will raise confidence. Each unexpected problem will force redesigns. That iterative process is how complex systems eventually mature. For now the concept remains a set of ambitious targets supported by early modular experiments. The real proof will come only when a vehicle seals its hatches, slips beneath the surface, and stays there for the full two hours before climbing back onto dry land ready for the next phase of its mission.
Until that day arrives, the idea serves as a useful reminder that the boundaries between land and sea continue to blur. Vehicles that once stayed firmly on one side of that boundary are beginning to explore the space in between. How far that exploration goes, and how practical the results become, will shape the options available to military planners for decades to come. The research teams working on this project have set themselves a difficult but fascinating challenge. The rest of us can only watch, learn, and consider what the eventual answers might mean for the future of coastal and riverine operations.